Ruihan Zhao 赵瑞涵

同济大学中德工程学院 讲师

赵瑞涵

我自 2026 年 1 月起任同济大学中德工程学院讲师。2025 年在同济大学获博士学位,2021 年在同济大学中德学院获硕士学位,导师均为李鹏忠。2024 年在慕尼黑工业大学 Autonomous Vehicle Systems(AVS)教席联合培养,合作导师为 Johannes Betz 教授。

我的研究方向是人机协作(HRC)装配,重点关注兼顾安全、效率与人因的自适应任务分配与规划。我结合多目标进化优化、强化自学习与模糊聚类等方法,研究共享人机装配系统中的资源与任务协同规划。此外,我也从事差分进化算法设计与基准驱动的数值优化研究,应用包括风电场布局优化。

我是 RDEx 团队成员,该团队获 IEEE CEC 2025 数值优化竞赛四个赛道全部第一;也是 RDE 团队成员,获 IEEE WCCI 2024 数值优化竞赛银奖。近期一作论文发表于 Applied Soft Computing、Advanced Engineering Informatics 和 Robotics and Computer-Integrated Manufacturing,完整列表见论文页。

ORCID 0009-0009-8208-0377 ruihan_zhao@tongji.edu.cn

动态

2026-08-13合作论文(三目标风电场布局优化)收录于 IEEE ICCNSE 2026 会议论文集。
2026-05-14一作论文(共享人机协作系统中的自适应产品族构建)发表于 Applied Soft Computing。
2026-04-04RDEx 差分进化系列四篇技术报告(SOP / CSOP / MOP / CMOP)发布于 arXiv。
2025-09-04一作论文(人机协作资源与任务规划)收录于 IEEE RCAR 2025 会议论文集。
2025-06-17一作论文(以人为本的人机协作装配规划框架)发表于 Advanced Engineering Informatics。

精选论文

* 通讯作者。 精选一作论文与 JCR Q1 期刊论文。

Adaptive product family formation: A medoid-based fuzzy clustering method for mixed product assembly in the shared human–robot collaborative system

R. Zhao, S. Tao, Y. Zhou, X. Zhang, P. Li*

Applied Soft Computing, vol. 200, Art. no. 115419, 2026.

论文

引用 02024 JCR Q12024 IF 6.62024 CiteScore 14.5
IEEE RCAR

Human-robot Collaborative Resource and Task Planning for Assembly Systems with Self-learning Multi-objective Evolutionary Optimizer

R. Zhao, S. Tao, P. Li

IEEE International Conference on Real-time Computing and Robotics (RCAR 2025), pp. 1272–1277, 2025.

论文

引用 0

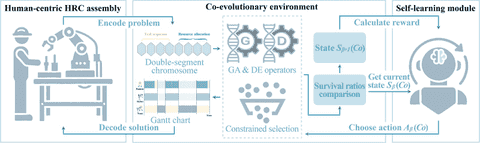
AEIFig. 1 of the paper: the human-centric HRC assembly problem is encoded for a co-evolutionary optimizer (double-segment chromosome, GA and DE operators, constrained selection) that is steered by a reinforcement self-learning module
论文图 1

Human-centric assembly planning framework for human–robot collaborative systems with efficient reinforcement self-learning multi-objective evolutionary optimizer

R. Zhao, S. Tao, P. Li*

Advanced Engineering Informatics, vol. 67, Art. no. 103508, 2025.

论文

引用 132025 JCR Q1 (Top 10%)2025 IF 9.92025 CiteScore 15.8

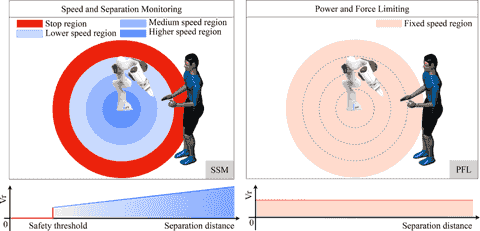
RCIMFig. 1 of the paper: speed and separation monitoring (SSM) versus power and force limiting (PFL), showing the robot speed regions around a human co-worker
论文图 1

Safety-efficiency integrated assembly: The next-stage adaptive task allocation and planning framework for human–robot collaboration

R. Zhao, S. Tao, P. Li*

Robotics and Computer-Integrated Manufacturing, vol. 94, Art. no. 102942, 2025.

论文

引用 212025 JCR Q12025 IF 11.42025 CiteScore 27.6

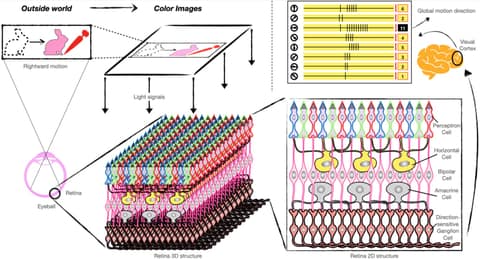
KBSFig. 1 of the paper: light from color images passes through the layered retina (photoreceptor, horizontal, bipolar, amacrine and direction-selective ganglion cells) to the visual cortex, which reports the global motion direction
论文图 1

A novel artificial visual system for motion direction detection in color images

S. Tao, Z. Zhang, R. Zhao, Z. Tang, Y. Todo*

Knowledge-Based Systems, vol. 295, Art. no. 111816, 2024.

论文

引用 52024 JCR Q12024 IF 7.62024 CiteScore 15.8

同济大学中德工程学院讲师,研究人机协作装配规划与进化优化。与其他同名研究者(如 UT Austin、UC Berkeley 的机器人学习方向,或医学影像方向)不是同一人。